Advisors: Dr. Saket Anand & Dr. Ojaswa Sharma · IIIT Delhi
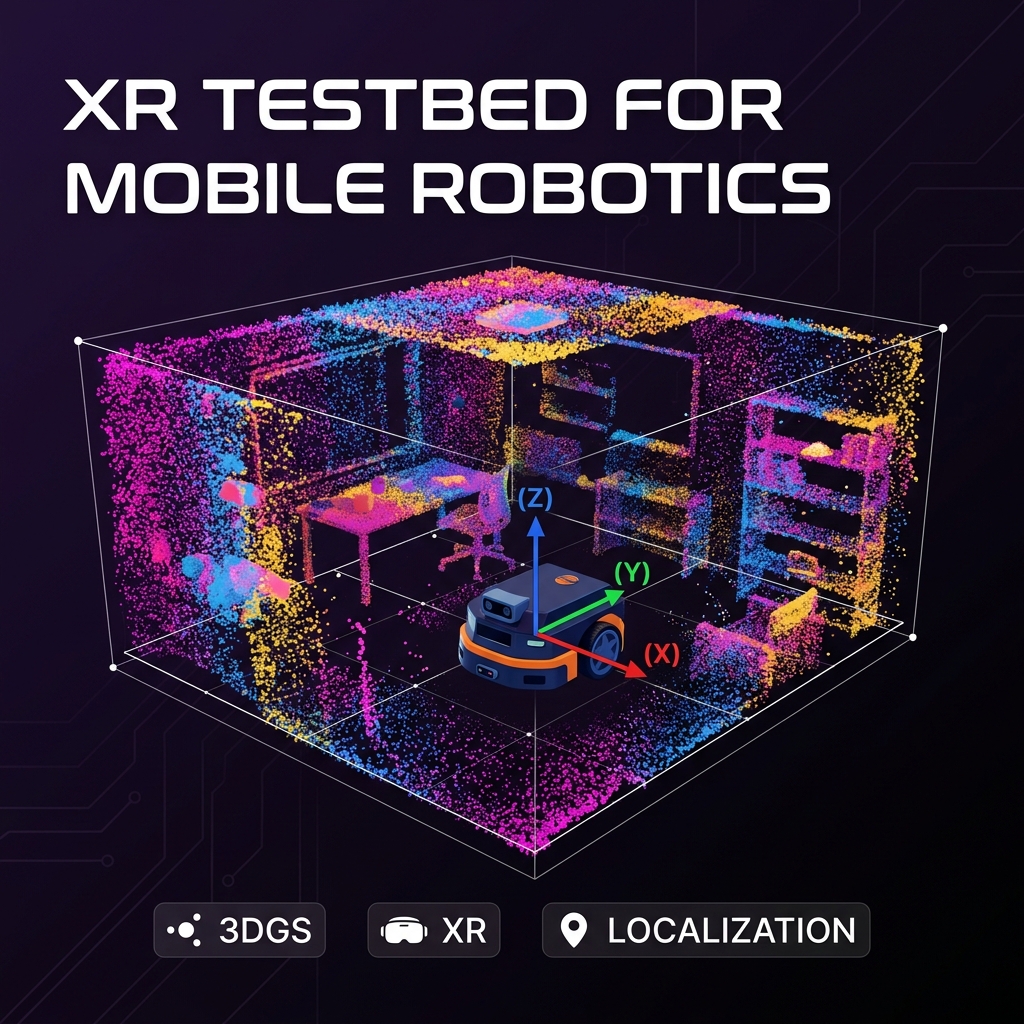
Building an Extended Reality (XR) testbed for mobile robotics by creating a high-fidelity static 3D digital twin of an indoor laboratory environment using 3D Gaussian Splatting (3DGS).
Overview
The goal is to create a photorealistic virtual replica of a physical lab space that a robot can use for localization, planning, and simulation — without needing expensive LiDAR rigs or dense sensor arrays.
3DGS represents scenes as millions of colored 3D Gaussians that can be rendered in real-time at high fidelity, making it a compelling alternative to traditional NeRF-based approaches for robotics applications.
What I’m Building
- 3D scene reconstruction of the IIITD Robotics lab using a multi-view image capture pipeline and Gaussian Splatting
- Multi-camera sensing pipeline for real-time robot localization and pose estimation within the reconstructed environment
- XR interface that overlays the digital twin on the physical space for remote monitoring and teleoperation
Results So Far
- Integrated multi-camera sensing pipelines for real-time robot localization and pose estimation within the reconstructed environment.
- Evaluating system robustness through latency, fault-tolerance, and performance testing under varying sensing and communication conditions.
Status
🔬 Ongoing — in active development with Prof. Saket Anand and Prof. Ojaswa Sharma.