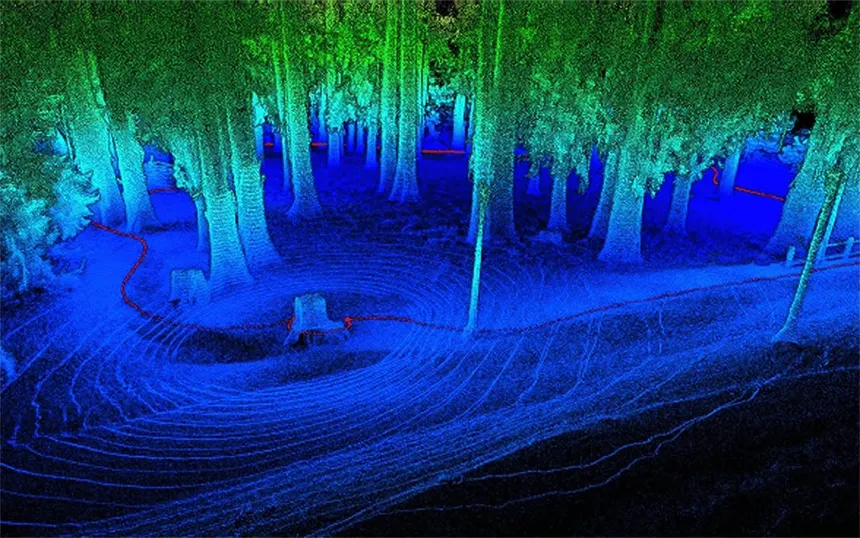
Learning better Point Cloud Representation using JEPA
A deep dive into converting raw 3D Point Clouds into Transformer tokens and exploring self-supervised pre-training strategies.
I’m a Computer Science undergraduate at IIIT Delhi, fascinated by robotics and how we can get an autonomous system to actually understand and navigate the world around it.
My research interests live at the intersection of computer vision and robot learning. I am particularly interested in moving away from heavy, expensive sensor suites towards systems that can perceive, reason, and act using just raw RGB video and clever machine learning.
I like working across the entire stack, from training novel architectures and dealing with ROS2 integration to squeezing models onto resource-constrained edge hardware. The long-term goal is pushing what robots can do in messy, unpredictable real-world environments without needing a sensor suite that costs more than my college fees.
A deep dive into converting raw 3D Point Clouds into Transformer tokens and exploring self-supervised pre-training strategies.