Advisor: Dr. Sayan Basu Roy · IIIT Delhi
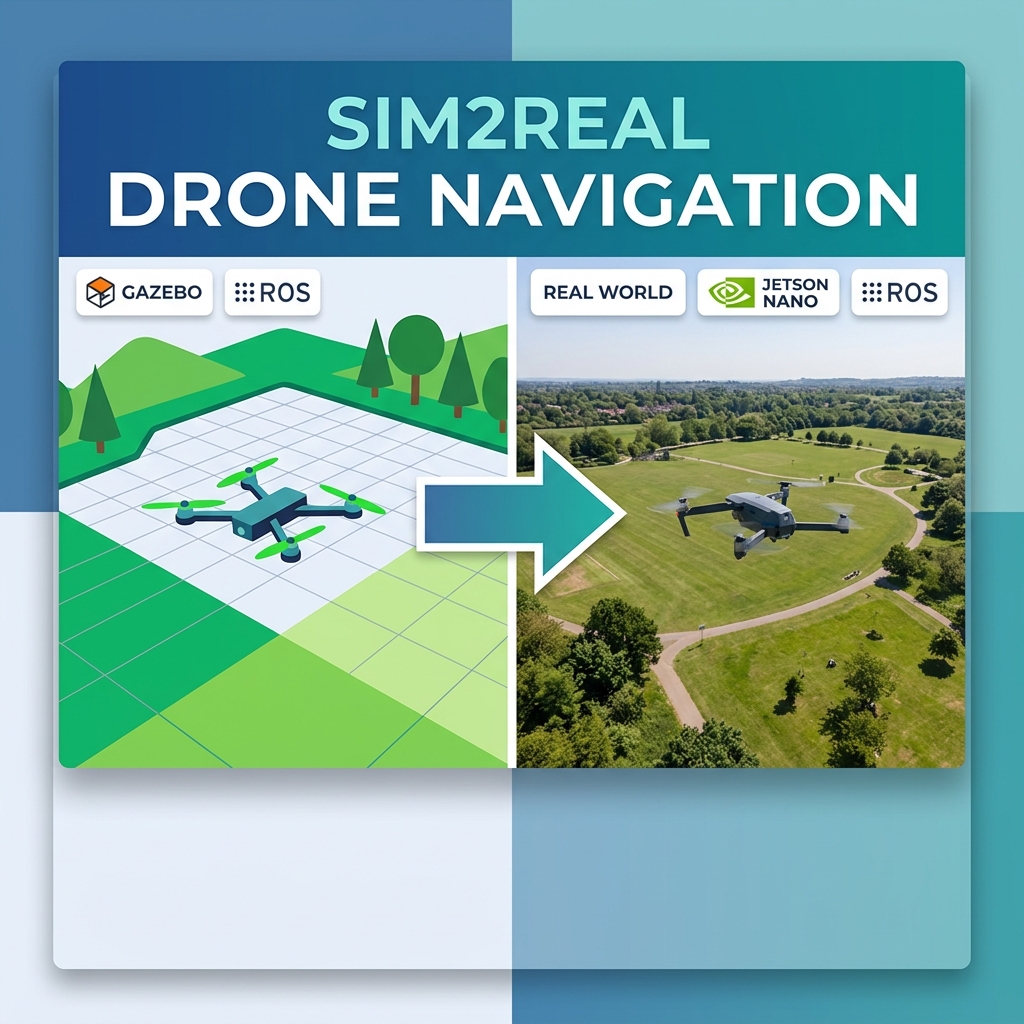
Architecting an end-to-end Sim2Real training pipeline for autonomous drone navigation — from synthetic data generation in simulation all the way to real-world edge deployment on an agricultural drone.
The Problem
Collecting real-world flight data is expensive, risky, and slow. Simulation offers virtually unlimited data at zero cost — but models trained in simulation often fail in the real world due to the “sim2real gap”: differences in lighting, physics, sensor noise, and visual appearance.
Approach
The pipeline uses ROS Noetic and Gazebo to generate diverse simulated flight trajectories, then trains deep neural control policies that generalize across the domain gap to real-world conditions.
Results
- Synthesized 10,000+ drone navigation data points across diverse virtual environments using ROS Noetic and Gazebo
- Trained and evaluated deep neural control policies, achieving a 15% improvement in trajectory tracking accuracy over CNN and LSTM baselines
- Deployed validated models onto an NVIDIA Jetson Nano-powered agricultural drone for autonomous on-board flight testing
Stack
| Component | Tool |
|---|---|
| Simulation | Gazebo + ROS Noetic |
| Policy training | PyTorch |
| Edge hardware | NVIDIA Jetson Nano |
| Control | Ackermann Pure-Pursuit |
Status
🔬 Ongoing — in active development with Dr. Sayan Basu Roy.